The Mini-Cheetah developed through the industry-academia cooperation with MIT professor Sangbae Kim’s research team is a four-legged robot capable of behaviors such as running, walking, jumping and turning. It boasts the quickest speed of all electric motor-based quadruped robots, and has been the focus of international attention due to its natural and dynamic locomotion, based on control architecture.
At the beginning of this year, professor Kim announced through various media outlets plans to produce and distribute multiple Mini-Cheetahs to other researchers. To do so, he has worked together with NAVER LABS to launch the MIT Mini-Cheetah Workshop.
The objective of this MIT Mini-Cheetah Workshop is to seek new challenges and opportunities in four-legged robots with robotics/AI engineers around the world, by sharing highly-advanced hardware and software functions.
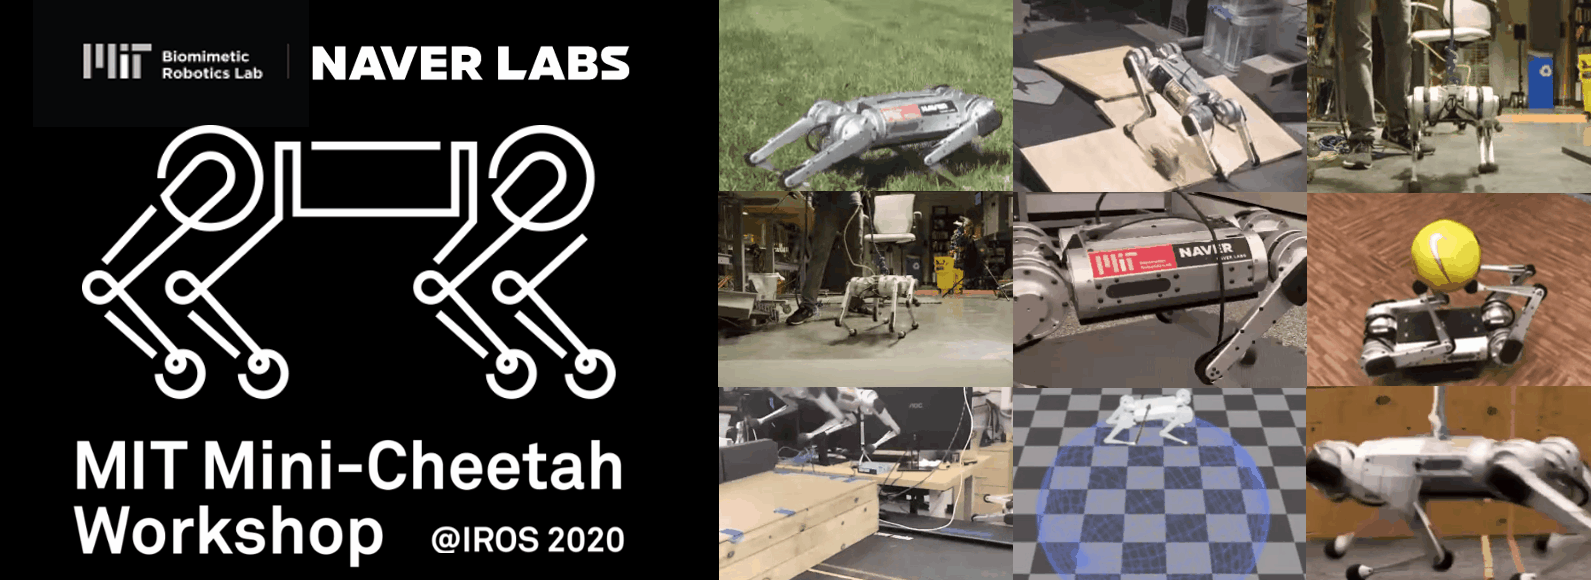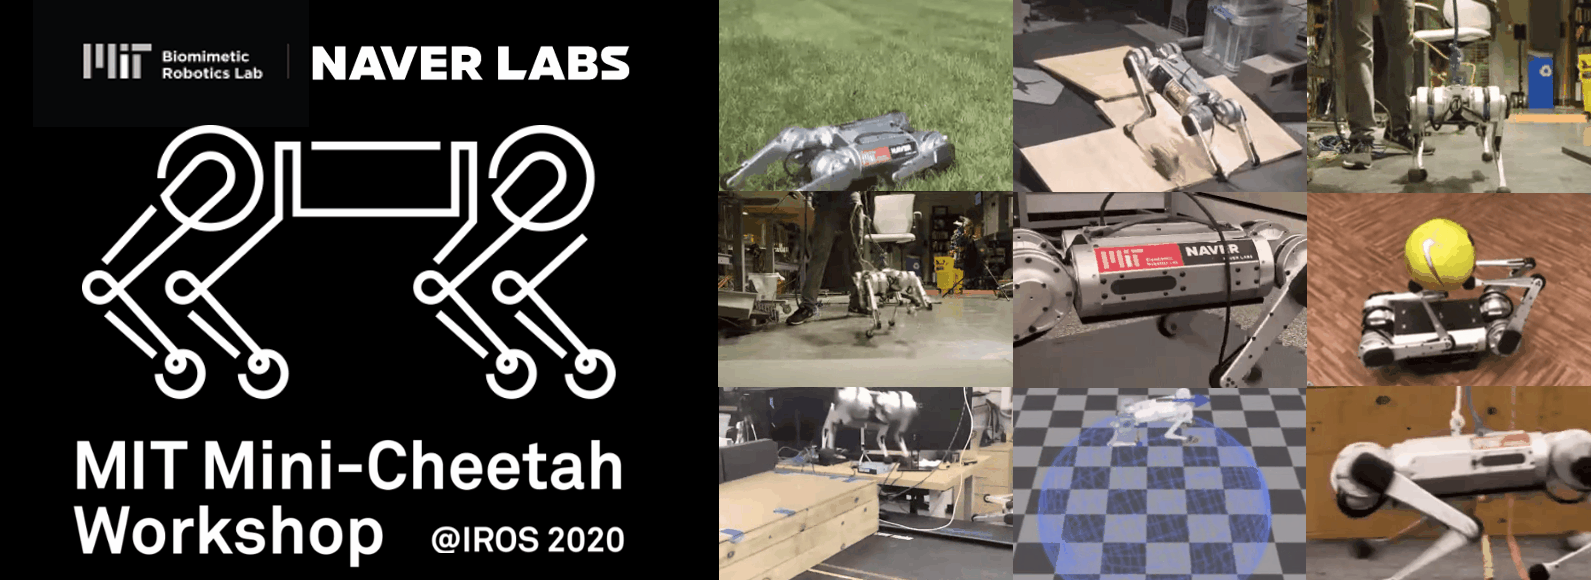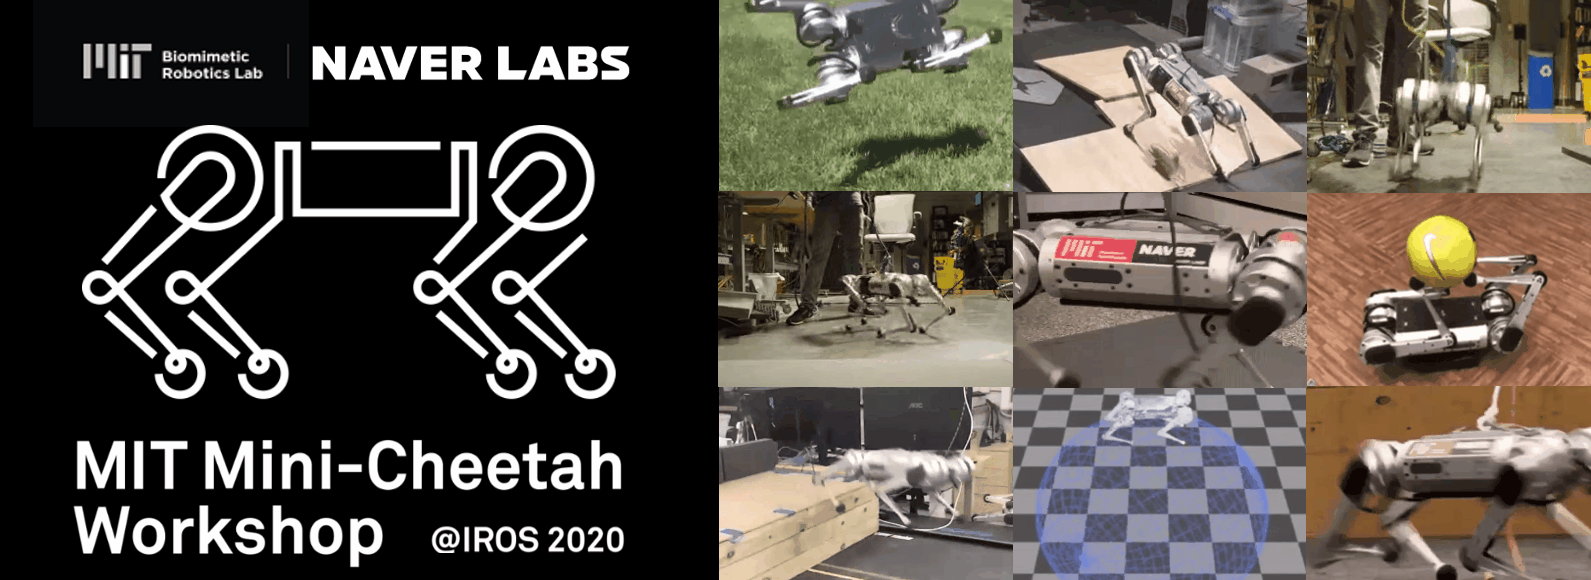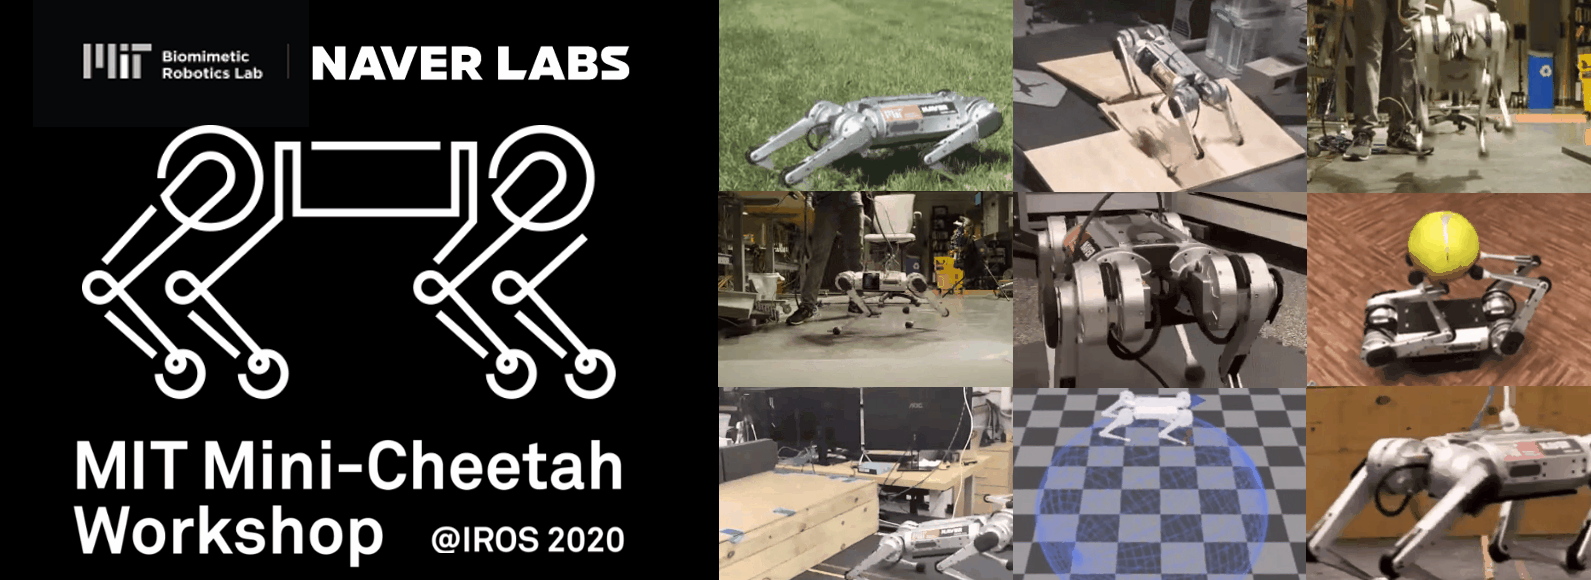
This workshop was held online via the International Conference on Intelligent Robots and Systems (IROS 2020). Many researchers studied new algorithms by testing the Mini-Cheetah robot hardware in person, and diverse discussions were held on the topic of quadrupedal robots, in 8 research sessions.
Click here to see the presentation video >
NAVER LABS has also been conducting research on improving the design and assembly structure, to widely distribute the Mini-Cheetah to many others for research purposes. We will continue to advance our technology by collaborating with MIT Biomimetics Robotics Lab and interacting with distinguished robotics/AI researchers around the world.